Keywords
- Reinforcement learning
- Deep reinforcement learning
- Robotic Manipulation Control
- DQN
- VGG16
Abstract
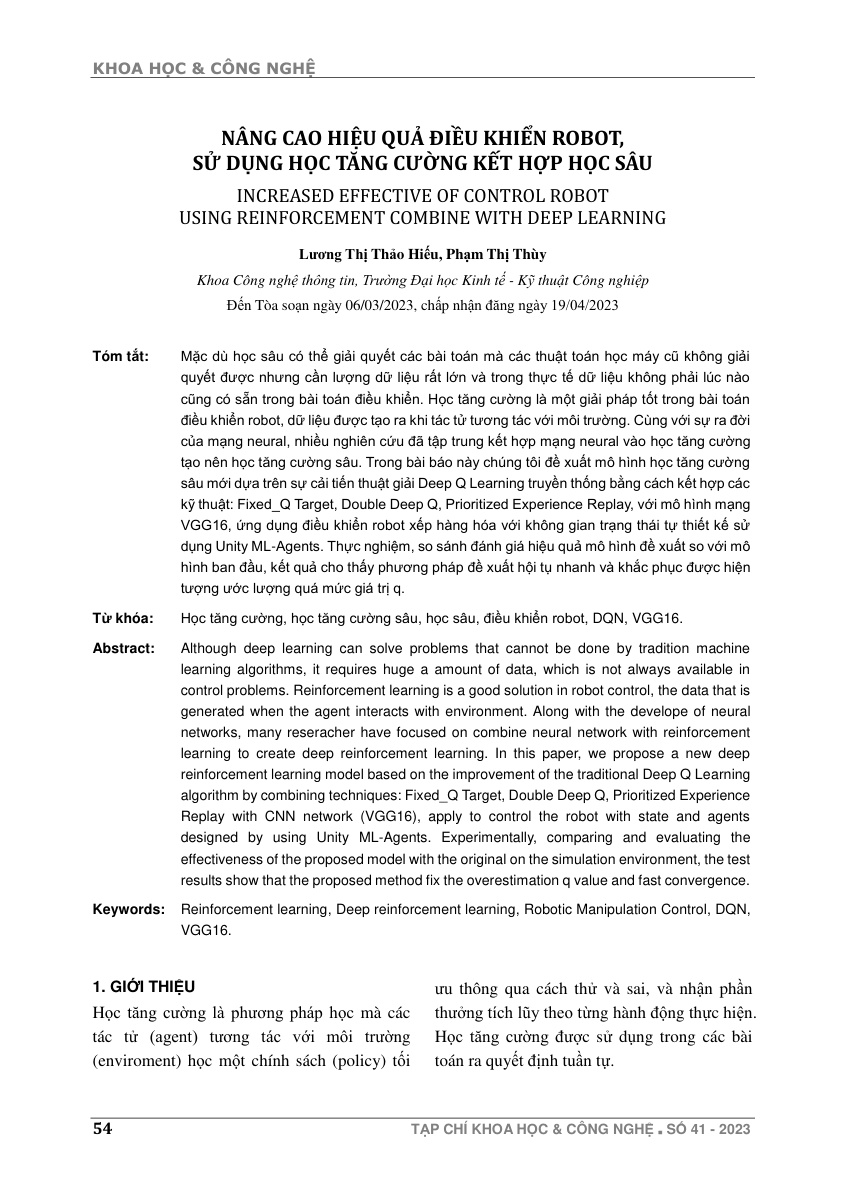
Although deep learning can solve problems that cannot be done by tradition machine learning algorithms, it requires huge a amount of data, which is not always available in control problems. Reinforcement learning is a good solution in robot control, the data that is generated when the agent interacts with environment. Along with the develope of neural networks, many reseracher have focused on combine neural network with reinforcement learning to create deep reinforcement learning. In this paper, we propose a new deep reinforcement learning model based on the improvement of the traditional Deep Q Learning algorithm by combining techniques: Fixed_Q Target, Double Deep Q, Prioritized Experience Replay with CNN network (VGG16), apply to control the robot with state and agents designed by using Unity ML-Agents. Experimentally, comparing and evaluating the effectiveness of the proposed model with the original on the simulation environment, the test results show that the proposed method fix the overestimation q value and fast convergence.Downloads
Download data is not yet available.
Published
2026-10-06
Issue
Section
Science & Technology